nature will has unveiled natura-1, a 50b-parameter moe model trained on human videos to control robotic hands with 20 joints.
how natura-1 works
nature will describes four parts of the setup:
- training data: ~1 million hours of first-person video, covering 61.7 million episodes, ~318,000 tasks and ~14,000 scenes.
- unified architecture: handles language, images, video and actions within a single model.
- fast response: the observation-to-action loop takes under 100 ms.
- hardware: tested on two-armed rokae ar5 robots fitted with wuji hands.
after pretraining on human video, the model is adapted to robots with what the company calls a limited amount of robot data.
natura-1 benchmark results
natura-1 scored 53.4 in base mode and 59.1 in agentic mode on the company's own 12-metric benchmark, using 20-joint robotic hands. on the same hands, neither π0.5 nor gpt-6-astra produced a scored result. on grippers, π0.5 scored 13.5 and gpt-6-astra 16.7.
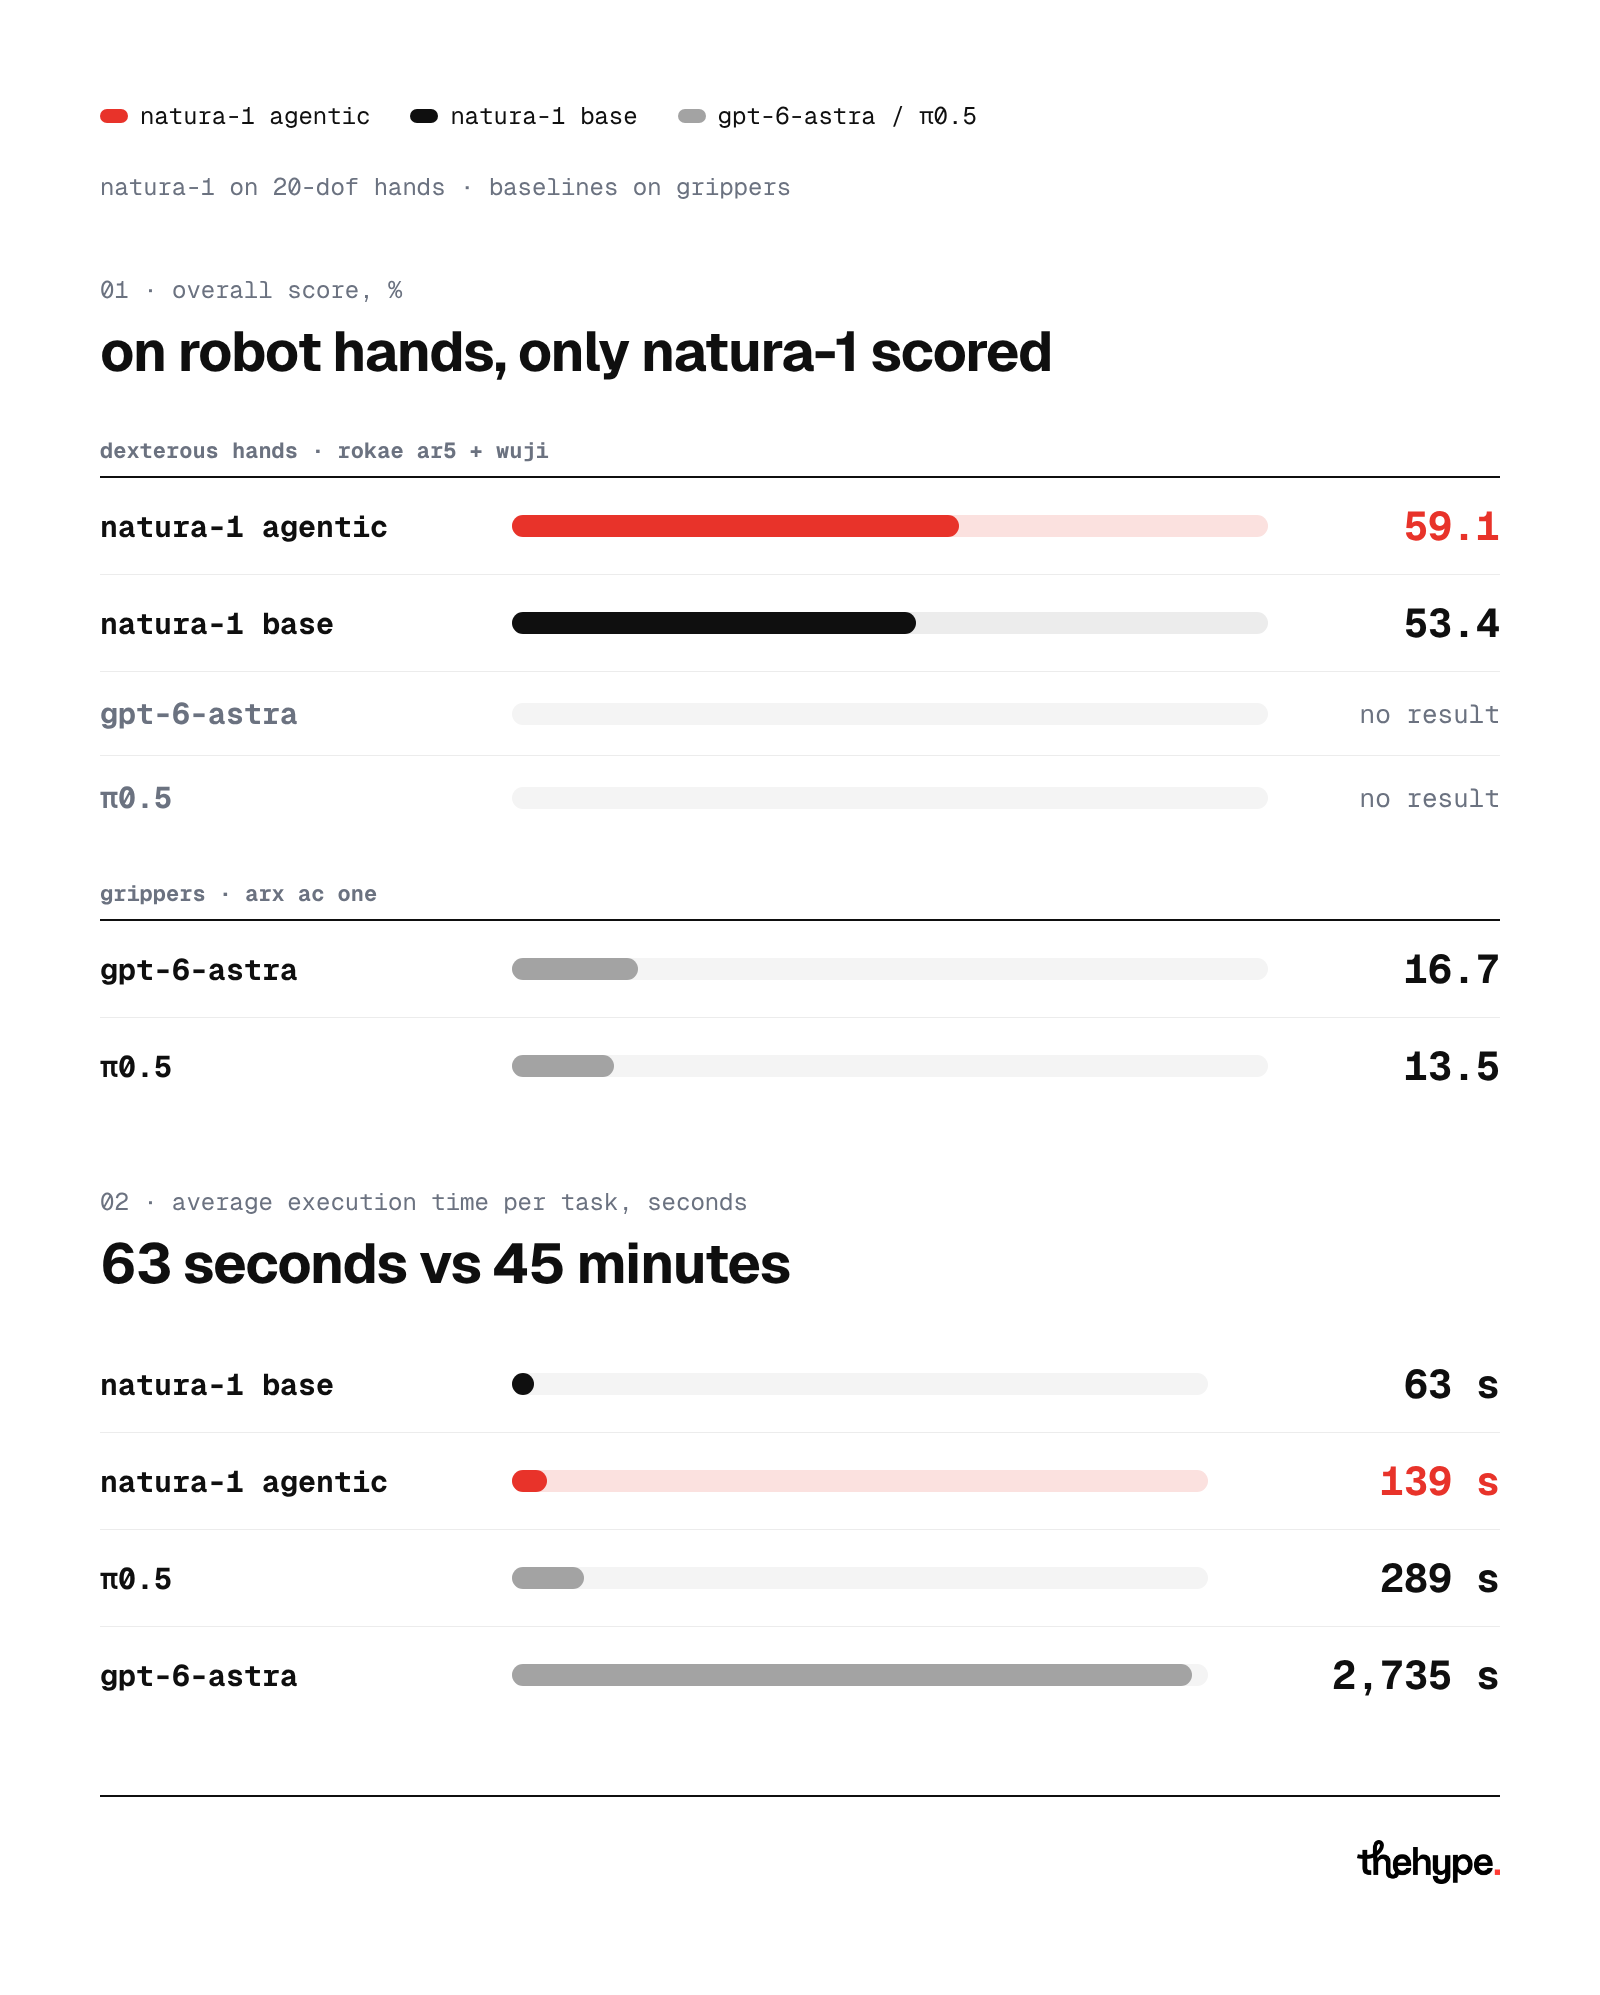
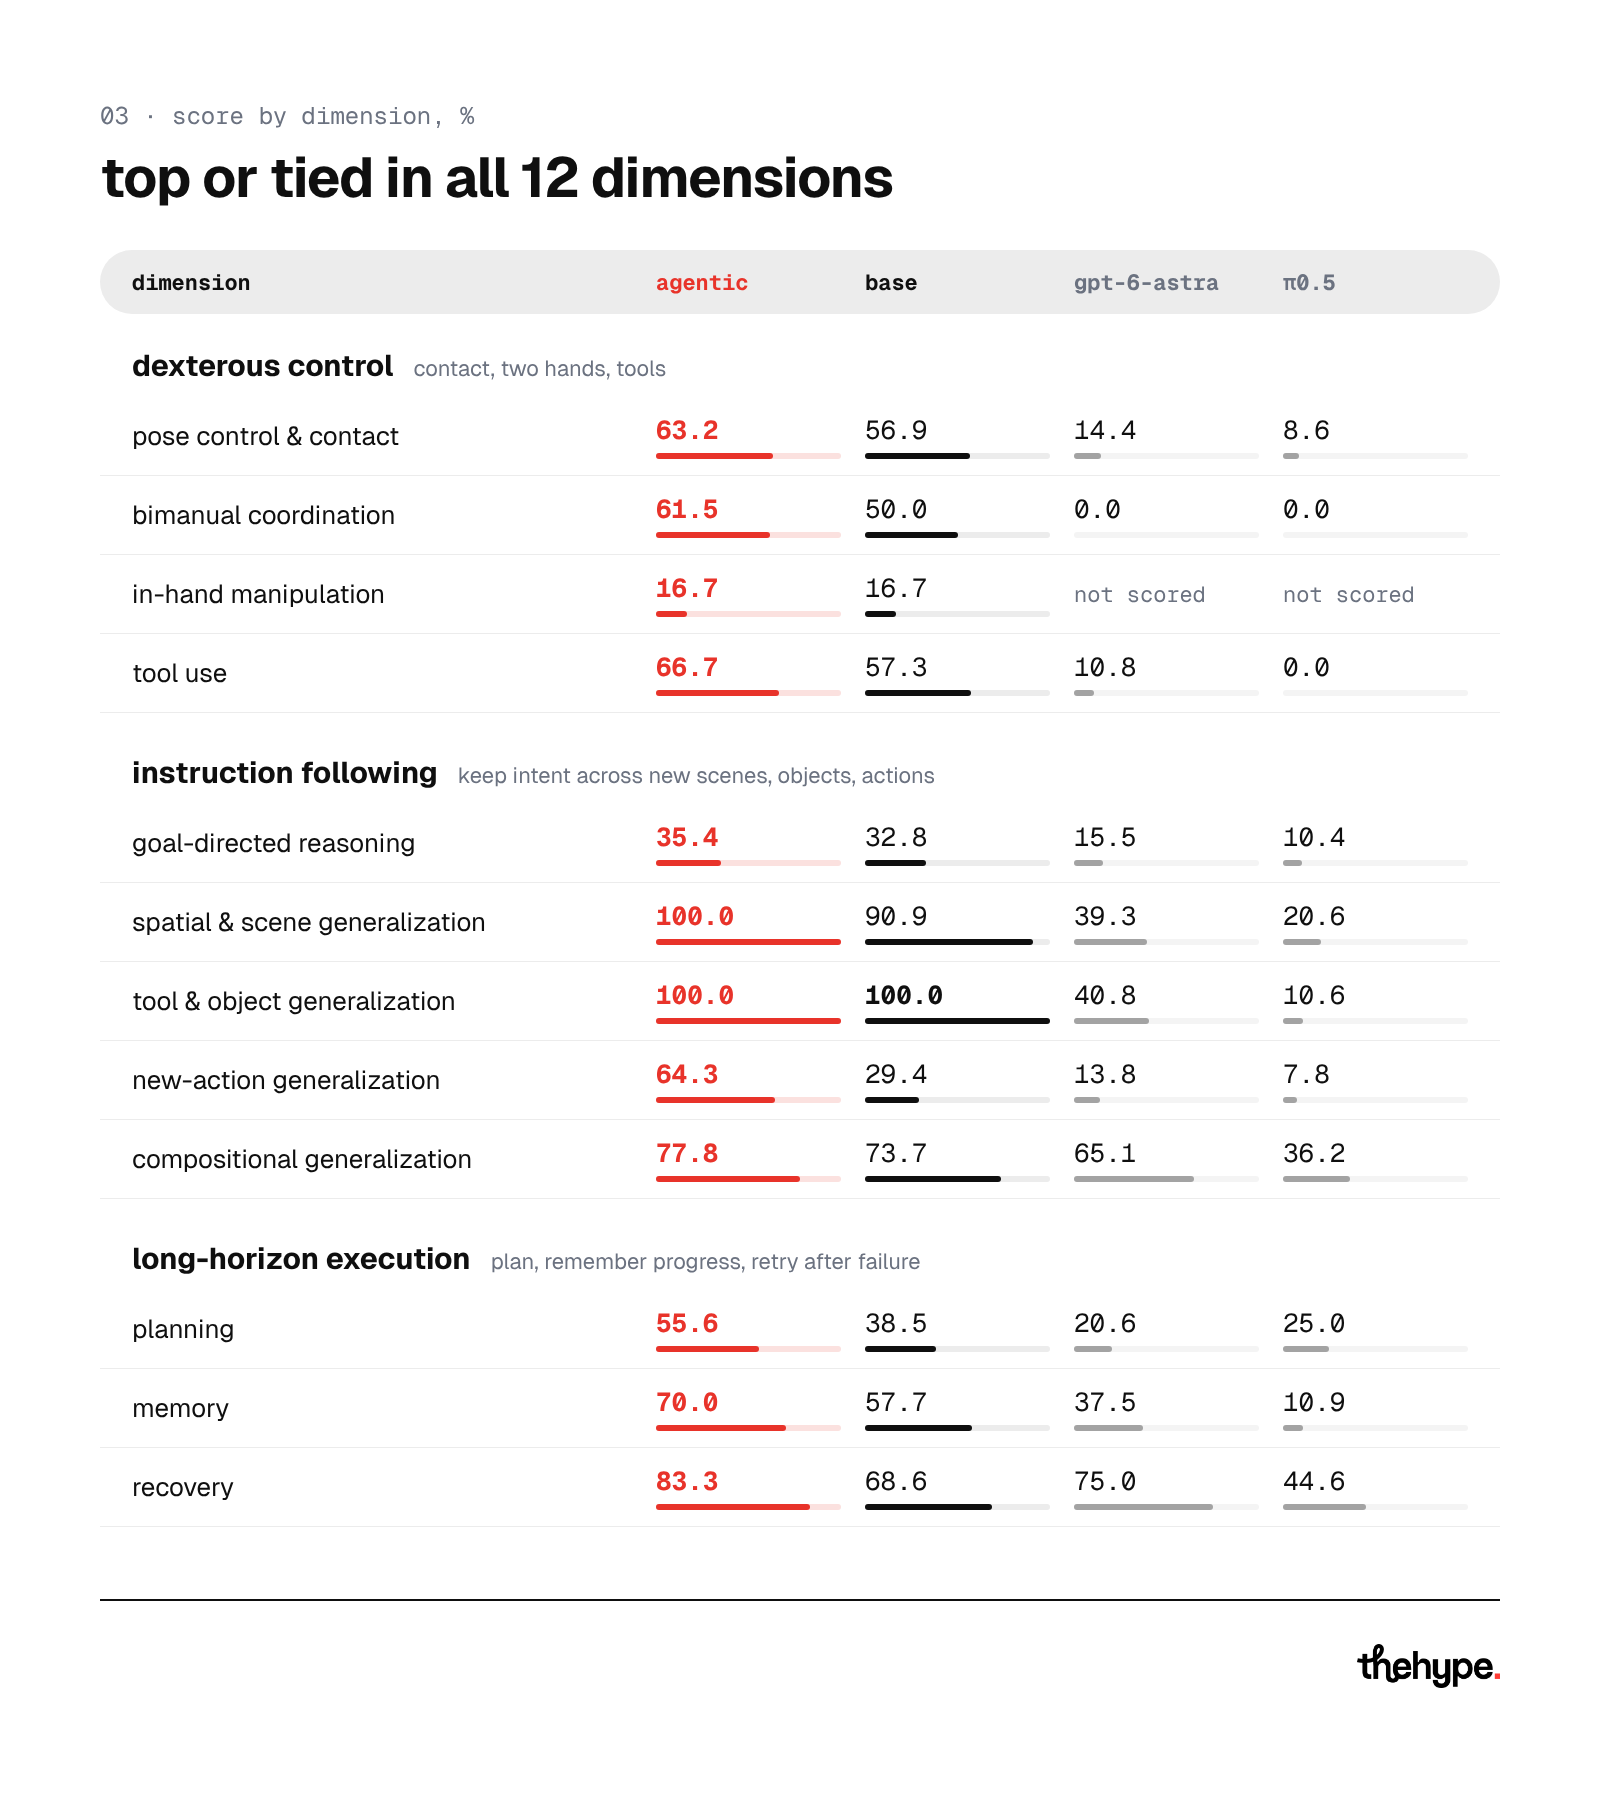
demos include folding dumplings, making tea, applying phone screen protectors and packing boxes. all six long-task demos required fine-tuning for specific tasks.
limitations and potential uses
the benchmark hasn't been independently verified, and the zero-shot demos come without success rates or attempt counts. nature will also hasn't disclosed how much robot data was used for fine-tuning.
natura-1 could be useful for repetitive work in small businesses, such as packing orders or preparing food. but first, it needs to show that it can handle unfamiliar objects and perform tasks reliably outside controlled demos.
sources
- the will to act – natura-1, nature will blog – training data, architecture, benchmark, demos
- nature will unveils natura-1, pandaily – oct 2026; company background, release